Abstract: A brand new research reveals that people possess a type of “distant contact,” permitting them to detect hidden objects in sand earlier than making direct contact. Contributors sensed buried cubes by perceiving tiny mechanical reflections generated as they moved their fingertips via the sand.
People carried out comparably to bodily fashions of most detectability and outperformed an LSTM-trained robotic sensor in precision. The invention expands our understanding of human tactile notion and gives a blueprint for designing superior robotic techniques able to delicate, vision-limited duties.
Key Information
- Human Distant Contact: Individuals can detect buried objects earlier than contact by sensing tiny mechanical disturbances in sand.
- Excessive Precision: People reached ~70% precision, outperforming a robotic that detected farther however produced extra false positives.
- Tech Inspiration: Findings supply benchmarks for bettering tactile-based robotics, assistive instruments, and exploration applied sciences.
Supply: Queen Mary College London
A research by researchers at Queen Mary College of London and College Faculty London has discovered that people have a type of distant contact, or the power to sense objects with out direct contact, a way that some animals have.
Human contact is often understood as a proximal sense, restricted to what we bodily contact. Nevertheless, current findings in animal sensory techniques have challenged this view. Sure shorebirds, akin to sandpipers and plovers, use a type of “distant contact” to detect prey hidden beneath the sand (du Toit et al. 2020; de Fouw et al. 2016).

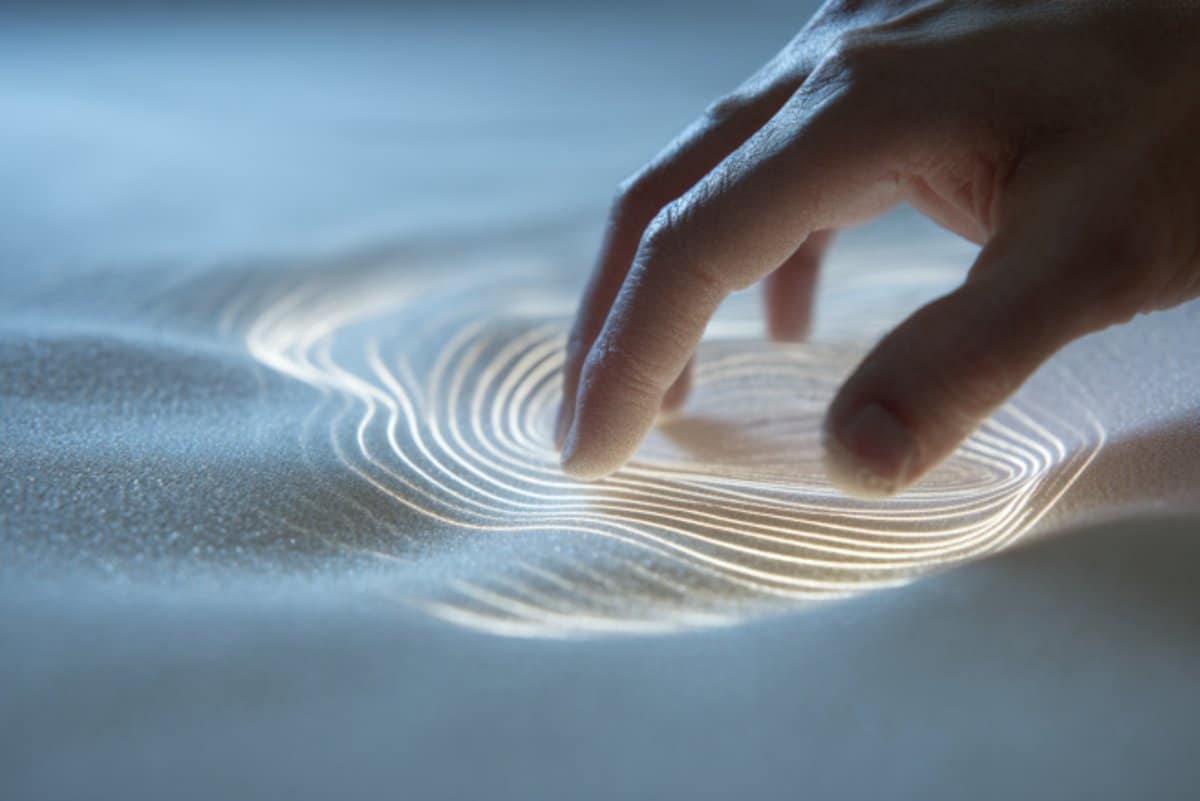
Distant contact permits the detection of objects buried below granular supplies via delicate mechanical cues transmitted via the medium, when a shifting strain is utilized close by.
The research in IEEE Worldwide Convention on Improvement and Studying (ICDL) investigated whether or not people share the same functionality. Contributors moved their fingers gently via sand to find a hidden dice earlier than bodily touching it.
Remarkably, the outcomes revealed a comparable potential to that seen in shorebirds, regardless of people missing the specialised beak constructions that allow this sense in birds.
Outcomes present human palms have extra sensitivity than anticipated
By modelling the bodily features of the phenomenon, the research discovered that human palms are remarkably delicate, detecting the presence of buried objects by perceiving minute displacements within the sand surrounding them.
This sensitivity approaches the theoretical bodily threshold of what could be detected from mechanical “reflections” in granular materials, when there’s a sand motion that’s “mirrored” on a steady floor (the hidden object).
Do people or robots carry out higher on distant contact?
When evaluating a human’s efficiency with a robotic tactile sensor skilled utilizing a Lengthy Brief-Time period Reminiscence (LSTM) algorithm, people achieved a formidable 70.7% precision inside the anticipated detectable vary. Curiously, the robotic might sense objects from barely farther distances on common however typically produced false positives, yielding solely 40% total precision.
These findings verify that individuals can genuinely sense an object earlier than bodily contact, a shocking capability for a way that’s often involved with objects that enter in direct contact with us. Each people and robots carried out very near the utmost sensitivity predicted with bodily fashions and displacement.
Why is the research vital?
This analysis reveals that people can detect objects buried in sand earlier than precise contact, increasing our understanding of how far the sense of contact can attain. It gives quantitative proof for a tactile talent not beforehand documented in people.
The findings additionally supply helpful benchmarks for bettering assistive know-how and robotic tactile sensing. Through the use of human notion as a mannequin, engineers can design robotic techniques that combine natural-like contact sensitivity for real-world purposes akin to probing, excavation, or search duties the place imaginative and prescient is restricted.
What are the broader implications?
Elisabetta Versace, Senior Lecturer in Psychology and lead of the Ready Minds Lab at Queen Mary College of London who conceived the human experiments stated: “It’s the primary time that distant contact has been studied in people and it adjustments our conception of the perceptual world (what known as the “receptive subject”) in residing beings, together with people.”
Zhengqi Chen, PhD pupil of Superior Robotics Lab at Queen Mary College of London stated: : “The invention opens prospects for designing instruments and assistive applied sciences that stretch human tactile notion.
“These insights might inform the event of superior robots able to delicate operations, for instance finding archaeological artifacts with out injury, or exploring sandy or granular terrains akin to Martian soil or ocean flooring.
“Extra broadly, this analysis paves the best way for touch-based techniques that make hidden or hazardous exploration safer, smarter, and simpler.”
Lorenzo Jamone, Affiliate Professor in Robotics & AI at College Faculty London, stated:
“What makes this analysis particularly thrilling is how the human and robotic research knowledgeable one another. The human experiments guided the robotic’s studying method, and the robotic’s efficiency supplied new views for deciphering the human knowledge.
“It’s an incredible instance of how psychology, robotics, and synthetic intelligence can come collectively, exhibiting that multidisciplinary collaboration can spark each basic discoveries and technological innovation.”
The research:
Researchers carried out two research: the primary, a human research assessing fingertip sensitivity to tactile cues from buried objects; the second, a robotic experiment utilizing a tactile-equipped robotic arm and a Lengthy Brief-Time period Reminiscence mannequin to detect object presence.
The authors are Zhengqi Chen, PhD pupil of Superior Robotics Lab, Dr Laura Crucianelli Lecturer in Psychology, Dr Elisabetta Versace, Senior Lecturer in Psychology, all from Queen Mary College of London and Lorenzo Jamone, Affiliate Professor in Robotics and AI at College Faculty London.
Key Questions Answered:
A: People can detect buried objects in sand earlier than making bodily contact, exhibiting a type of “distant contact” beforehand identified solely in sure animals.
A: Minute mechanical displacements in sand “mirror” off hidden objects, and the human hand can choose up these delicate cues whereas shifting via the fabric.
A: People achieved about 70% precision inside the detectable vary, outperforming a robotic that sensed objects barely farther away however produced many false positives.
About this tactile notion and neuroscience analysis information
Creator: Lucia Graves
Supply: Queen Mary College London
Contact: Lucia Graves – Queen Mary College London
Picture: The picture is credited to Neuroscience Information
Authentic Analysis: Closed entry.
“Exploring Tactile Notion for Object Localization in Granular Media: A Human and Robotic Research” by Elisabetta Versace et al. IEEE Worldwide Convention on Improvement and Studying
Summary
Exploring Tactile Notion for Object Localization in Granular Media: A Human and Robotic Research
Localizing buried objects in granular media, akin to sand, poses a big problem in robotics, with restricted perception into human tactile capabilities in these environments.
This research presents a novel method to tactile-based localization via: (1) a human research with 12 members assessing fingertip sensitivity to tactile cues from buried objects, and (2) a robotic experiment utilizing a tactile-equipped robotic arm and a Lengthy Brief-Time period Reminiscence (LSTM) mannequin to detect object presence.
Drawing from granular media particle interplay idea, we hypothesize tactile cues lengthen as much as 7 cm.
Human outcomes verify detection with 70.7% precision at a 6.9 cm distance (median 2.7 cm). Robotic outcomes align, with the LSTM mannequin detecting objects at 7.1 cm, although with a greater median (6 cm) however decrease precision (40%).
This work enhances understanding of human tactile notion in granular media and introduces a robotic system to review human exploration methods and allow autonomous purposes in archaeology, area exploration, and search and rescue.